Overview
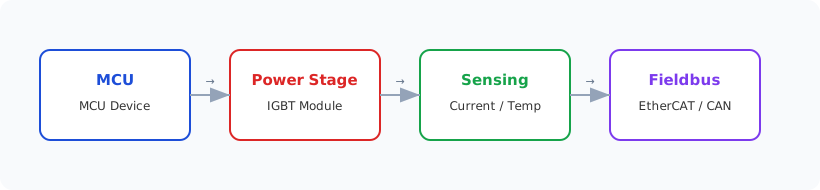
A motor drive turns a DC or a rectified bus into a variable-frequency waveform that controls the speed and the torque of a motor, and it needs three things: a power stage that switches the current, a controller that generates the waveform and a measurement that closes the loop. BYD Semiconductor supplies all three with its intelligent power modules, its IGBT modules and its automotive-grade MCUs, and BeiLuo supplies them with genuine traceability and FAE support. This page shows how the parts fit together in a motor drive, from an appliance compressor to an industrial pump.
The Inverter Stage
The inverter stage converts the DC bus into the three-phase output, and a BYD intelligent power module (IPM) is the compact way to build it. The IPM integrates the three-phase IGBT bridge, the high-side and low-side gate drivers, the bootstrap diodes and the protection on one package, so the power stage is a single part that mounts on a heat sink and takes a few logic signals. That removes the risk of a mis-designed gate loop and the long list of external components that a discrete bridge would need.
Choosing the IPM
The IPM is chosen by the bus voltage and the motor current. A BYD IPM in the 600 V class covers a mains-fed motor, and the 10 A, 15 A and 30 A options cover a fan, a pump, an appliance compressor and a small industrial motor. Size the rating above the motor's RMS phase current with margin for the peak and the start-up, and size the heat sink for the RMS current at the worst-case ambient. The built-in protection, under-voltage lockout and over-current, and the fault output, improve the reliability of the finished drive.
The Controller
The controller generates the PWM and runs the control loop, and a BYD MCU is a natural fit. The 32-bit BF7006 series offers an ARM Cortex-M0 core, embedded flash, a multi-channel 12-bit ADC and flexible timers in a package from 48 to 64 pins, and it is AEC-Q100 Grade 1 with a -40 °C to +125 °C range. The timers can produce the complementary PWM with dead-time for the three half bridges, and the ADC samples the current and the bus voltage for the field-oriented or the volt-per-hertz control loop. For a simple fan or a light the 8-bit BF7112A is enough.
Control Loop and Protection
The firmware closes the loop on the current and the speed, and it uses the IPM fault output and the measured current to detect a stall or an over-current and to shut the drive down safely. Because the controller and the power stage come from one supplier, the timing and the interface are well matched, and a smaller board results.
Current Sensing
The current measurement closes the torque loop and enables the protection. A low-cost drive uses a shunt in the DC link or the low-side legs, and a higher-performance drive uses a BYD isolated current sensor, which measures the current without a shunt and with isolation in one package. The BYD current sensor provides an analog output proportional to the current for the ADC, and it stays accurate and free of wear over a long service life.
Thermal Design
At the module level the thermal design decides the reliability, so mount the IPM on a heat sink with the recommended interface, keep the RMS current within the rating for the ambient and measure the case temperature at the worst case. A cooler module lives longer and derates less.
Getting Help
Send your motor type, bus voltage, current, control method and environment to our FAE team and we will propose an IPM, an MCU and a current sensor, help set the current rating and the control loop and review the thermal design. BeiLuo holds mainstream BYD IPMs, MCUs and sensors in regional warehouses and ships every order with an import declaration, a certificate of origin and a RoHS compliance file, so a motor drive design can move from prototype to production without a supply gap.